Page Not Found
Page not found. Your pixels are in another canvas. Read more
A list of all the posts and pages found on the site. For you robots out there is an XML version available for digesting as well.
Page not found. Your pixels are in another canvas. Read more
This is a page not in th emain menu Read more
Published:
This post will show up by default. To disable scheduling of future posts, edit config.yml and set future: false. Read more
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool. Read more
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool. Read more
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool. Read more
Published:
This is a sample blog post. Lorem ipsum I can’t remember the rest of lorem ipsum and don’t have an internet connection right now. Testing testing testing this blog post. Blog posts are cool. Read more
Short description of portfolio item number 1 Read more
Short description of portfolio item number 2 Read more

Published in Preprint, 2021
This paper proposes an efficient data structure, ikd-Tree, for dynamic space partition. The ikd-Tree incrementally updates a k-d tree with new coming … Read more
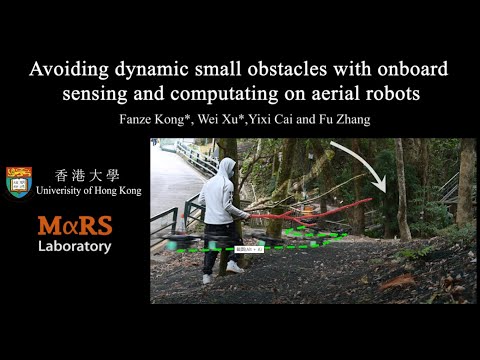
Published in IEEE Robotics and Automation Letters (RAL), 2021
In practical applications, autonomous quadrotors are still facing significant challenges, such as the detection and avoidance of very small and even … Read more

Published in IEEE Transactions on Control Systems Technology (TCST), 2022
This article presents a generic motion model to capture mobile robots' dynamic behaviors (translation and rotation). The model is based on … Read more

Published in IEEE Transactions on Robotics (TRO), 2022
This article presents FAST-LIO2: a fast, robust, and versatile LiDAR-inertial odometry framework. Building on a highly efficient tightly coupled … Read more
Published in IEEE/ASME Transactions on Mechatronics (TMECH), 2022
Unmanned aerial vehicles (UAV) are widely used in the field for tasks that require 3-D movements in space. The simultaneous demand for heavy payload … Read more

Published in Science Robotics, 2023
Uncrewed aerial vehicles (UAVs) rely heavily on visual sensors to perceive obstacles and explore environments. Current UAVs are limited in both … Read more

Published in IEEE Robotics and Automation Letters (RAL), 2023
The emergence of LiDAR sensors have brought new opportunities for autonomous unmanned aerial vehicles (UAVs) by advancing navigation safety and … Read more

Published in IEEE Transactions on Robotics (TRO), 2023
In this paper, we propose a novel LiDAR(-inertial) odometry and mapping framework to achieve the goal of simultaneous localization and meshing in … Read more

Published in International Journal of Robotics Research, 2023
We address the theoretical and practical problems related to the trajectory generation and tracking control of tail-sitter UAVs. Theoretically, we … Read more

Published in IEEE Transactions on Robotics (TRO), 2023
Occupancy mapping is a fundamental component of robotic systems to reason about the unknown and known regions of the environment. This article … Read more

Published in International Journal of Robotics Research, 2023
In recent years, advancements in Light Detection and Ranging (LiDAR) technology have made 3D LiDAR sensors more compact, lightweight, and affordable. … Read more
Published in IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS 2024), 2024
Recent advances in LiDAR technology have opened up new possibilities for robotic navigation. Given the widespread use of occupancy grid maps (OGMs) … Read more

Published in IEEE Robotics and Automation Letters (RAL), 2024
This paper introduces LAMM, an open-source framework for large-scale multi-session 3D LiDAR point cloud map merging. LAMM can automatically integrate … Read more

Published in IEEE Transactions on Robotics (TRO), 2024
Aerial swarm systems possess immense potential in various aspects, such as cooperative exploration, target tracking, search and rescue. Efficient, … Read more

Published in IEEE Transactions on Robotics (TRO), 2024
Trajectory generation for fully autonomous flights of tail-sitter unmanned aerial vehicles (UAVs) presents substantial challenges due to their highly … Read more

Published in 2025 IEEE International Conference on Robotics and Automation (ICRA), 2025
Point cloud maps with accurate color are crucial in robotics and mapping applications. Existing approaches for producing RGB-colorized maps are … Read more

Published in 2025 IEEE International Conference on Robotics and Automation (ICRA), 2025
This paper presents a unified surface reconstruction and rendering framework for LiDAR-visual systems, integrating Neural Radiance Fields (NeRF) and … Read more

Published in Science Robotics, 2025
Micro air vehicles (MAVs) capable of high-speed autonomous navigation in unknown environments have the potential to improve applications like search … Read more

Published in Robotics: Science and Systems (RSS) 2025, 2025
This research tackles the challenge of real-time active view selection and uncertainty quantification on visual quality for active 3D reconstruction. … Read more

Published in Robotics and Automation Letters (RA-L), 2025
This paper presents a lightweight LiDAR-inertial-visual odometry system optimized for resource-constrained platforms. It integrates a … Read more

Published in International Conference on Intelligent Robots and Systems (IROS 2025), 2025
Navigating an arbitrary-shaped ground robot safely in cluttered environments remains a challenging problem. The existing trajectory planners that … Read more

Published in International Conference on Computer Vision (ICCV 2025), 2025
Moving object segmentation (MOS) on LiDAR point clouds is crucial for autonomous systems like self-driving vehicles. Previous supervised approaches … Read more

Published in Nature Communications, 2025
Landslides pose significant threats to residents’ safety and daily lives. To mitigate such risks, flexible debris-resisting barriers are constructed … Read more

Published in Transactions on Robotics (T-RO), 2025
Mobile robots have revolutionized various fields, offering solutions for manipulation, environmental monitoring, and exploration. However, payload … Read more

Published in Transactions on Mechatronics (T-Mech), 2025
This survey offers a comprehensive overview of recent advancements in LiDAR-based autonomous uncrewed aerial vehicles (UAVs), covering their design, … Read more

Published in NeurIPS 2025 (Spotlight), 2025
Previous dominant methods for scene flow estimation focus mainly on input from two consecutive frames, neglecting valuable information in the … Read more
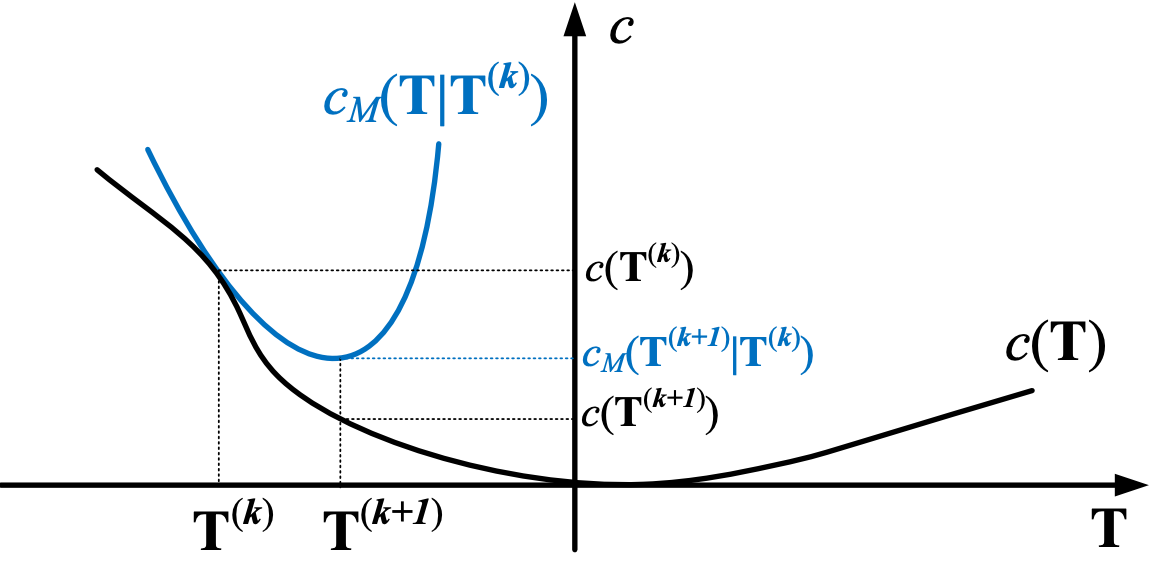
Published in International Journal of Robotics Research, 2025
Point cloud bundle adjustment is critical in large-scale point cloud mapping. However, it is both computationally and memory intensive, with its … Read more

Published in Communications Engineering, 2025
The widespread adoption of multirotor uncrewed aerial vehicles (UAVs) is hindered by limited flight time and degraded stability to wind disturbances. … Read more

Published in IEEE Robotics and Automation Letters (RAL), 2025
3D mapping is vital for a broad range of applications that rely on a consistent and accurate representation of the environment. Change is an … Read more

Published in IEEE Robotics and Automation Letters (RAL), 2026
Accurate 3D scene flow estimation is critical for autonomous systems to navigate dynamic environments safely, but creating the necessary large-scale, … Read more

Published in International Journal of Robotics Research, 2026
Determining the occupancy status of locations in the environment is a fundamental task for safety-critical robotic applications. Traditional … Read more

Published in IEEE Robotics and Automation Letters (RAL), 2026
While end-to-end autonomous driving models show promising results, their practical deployment is often hindered by large model sizes, a reliance on … Read more
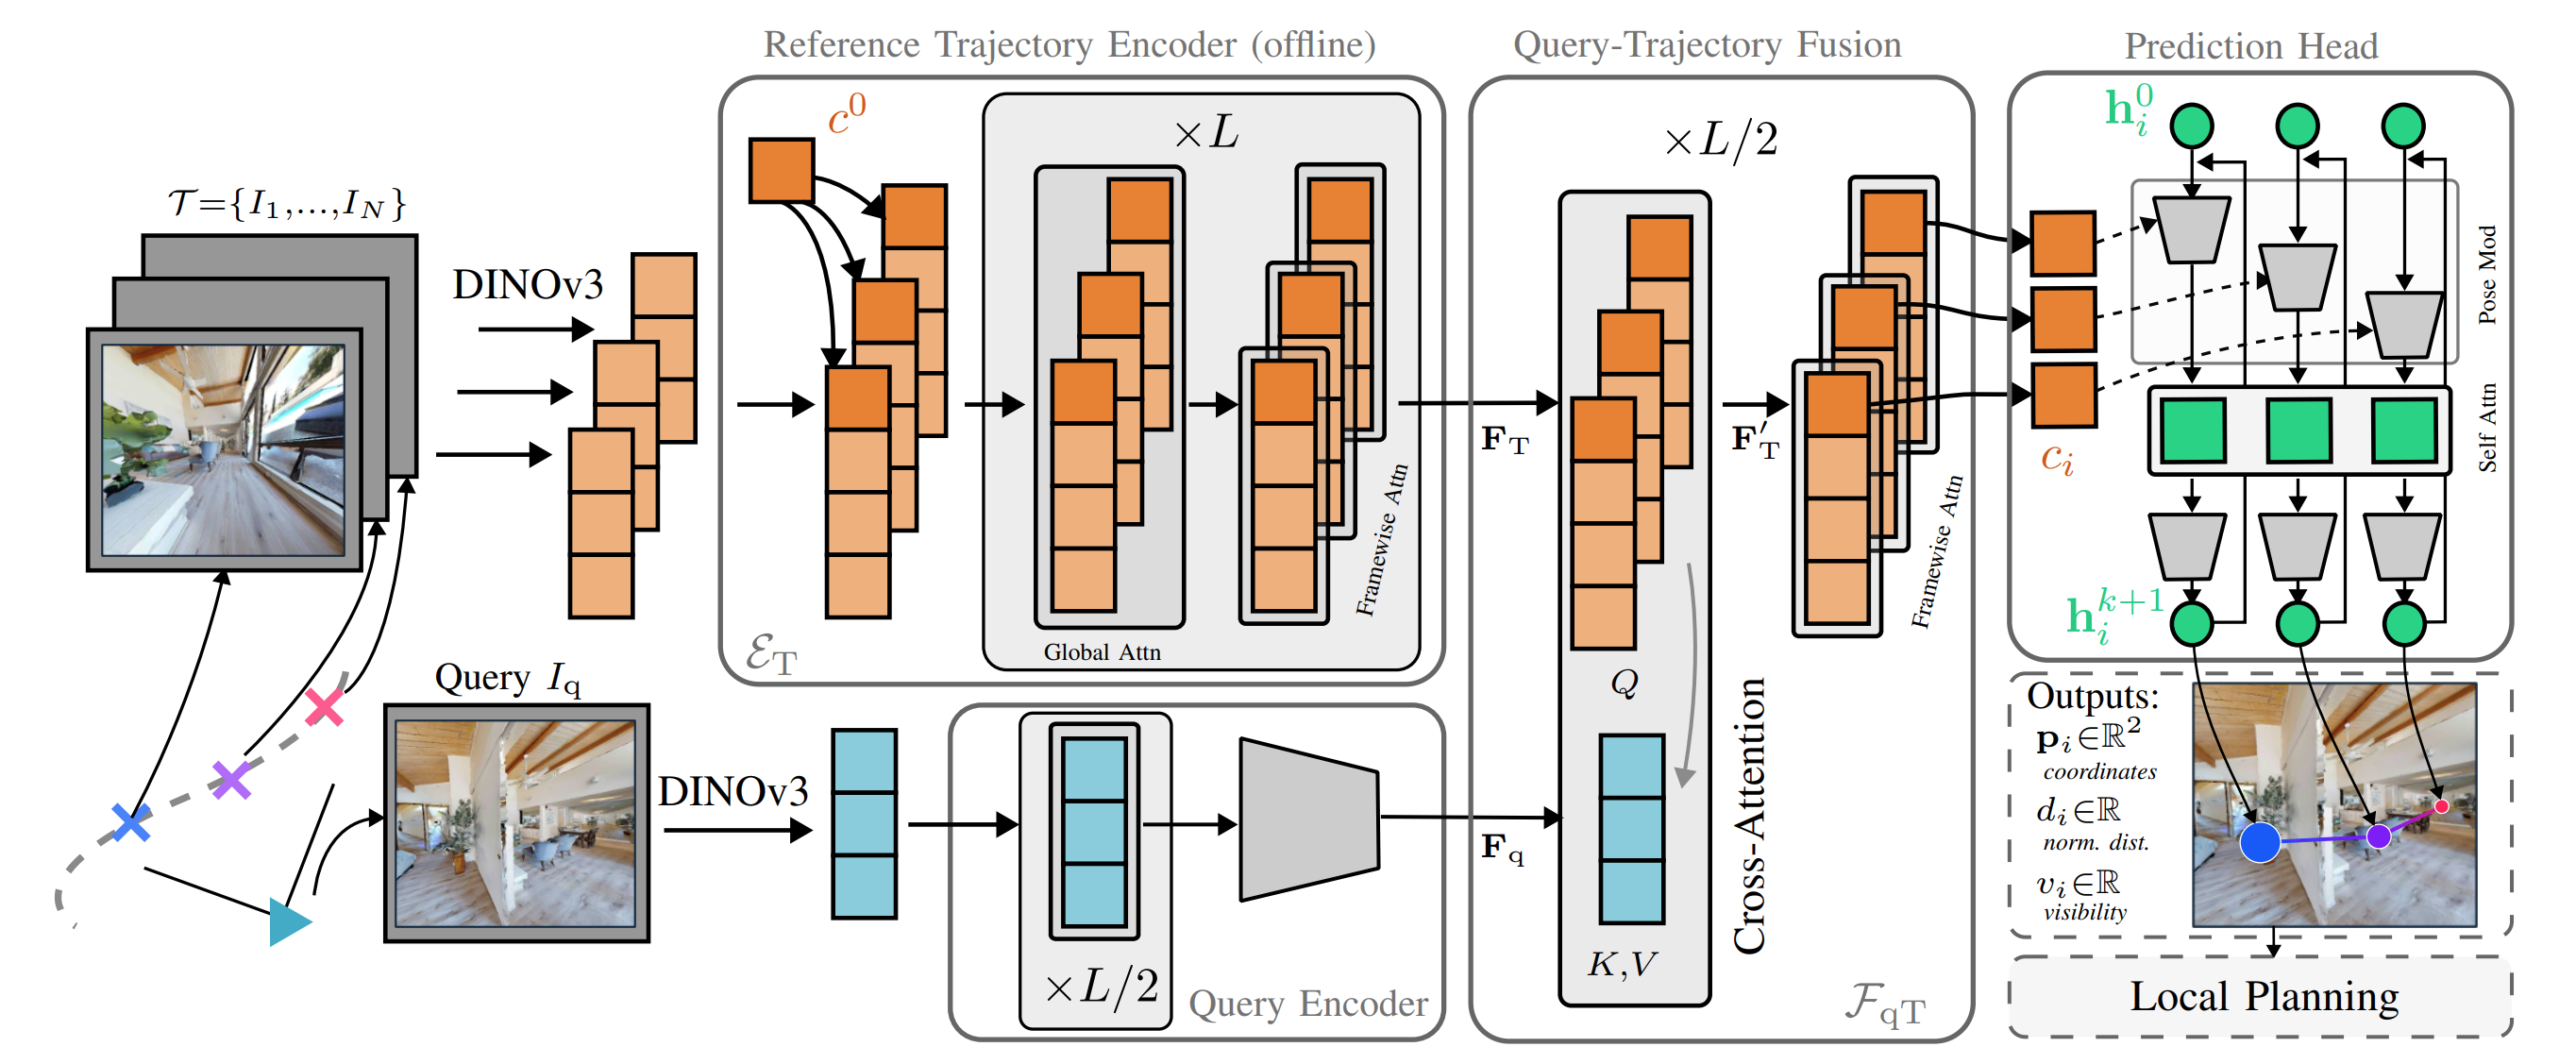
Published in Robotics: Science and Systems (RSS) 2026, 2026
We present LoTIS, a model for visual navigation that provides robot-agnostic image-space guidance by localizing a reference RGB trajectory in the … Read more
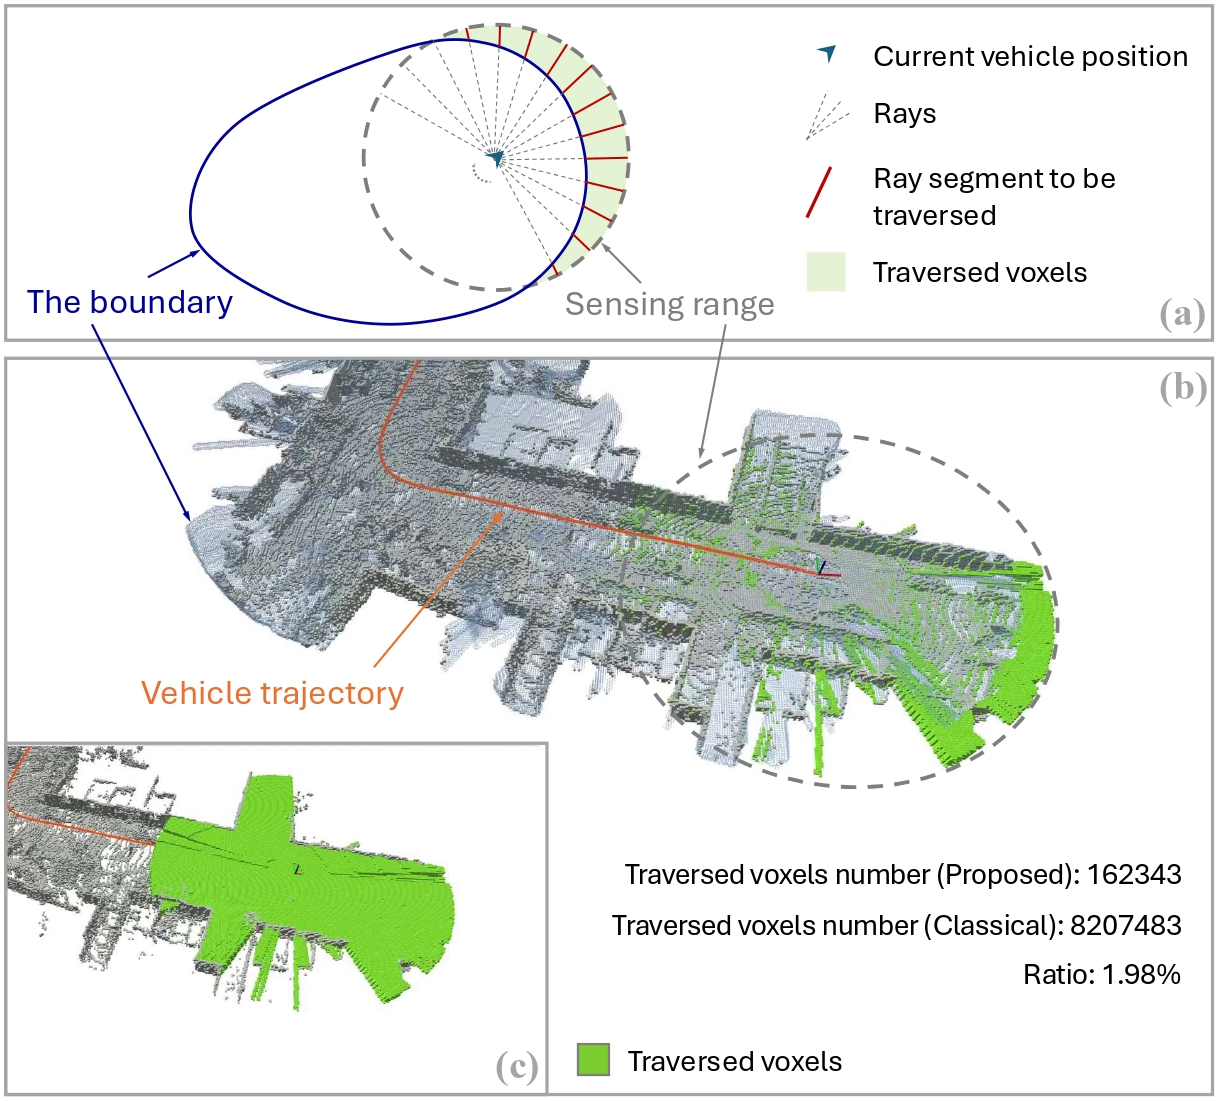
Published in IEEE Robotics and Automation Letters (RAL), 2026
Efficient and scalable 3D occupancy mapping is essential for autonomous robot applications in unknown environments. However, traditional occupancy … Read more

Published in IEEE Robotics and Automation Letters (RAL), 2026
In this letter we study 1v1 quadrotor pursuit-evasion, where a pursuer and an evader are trained via reinforcement learning (RL) by competing against … Read more
Published:
In October 2022, I had the privilege of showcasing FAST-LIO2 in International Conference on Intelligent Robots and Systems (IROS 2022), Kyoto, Japan. It was my first academic presentation in an international conference. I was truly inspired by the passion from the audience about our work and the insightful questions in the Q&A period. I’m delighted to see that FAST-LIO2 has been gaining increasing interest (and GitHub stars :>) since the conference, contributing to the advancement of LiDAR-inertial Odometry espicially in the aspect of incremental data structures. Read more
Teaching Assistant in Undergraduate Course, University of Hong Kong, Department of Mechanical Engineering, 2024
This course aims to cover: modelling of robot kinematics / dynamics; programming on robot embedded control units; characterization and specification of robot actuation; sensing interface for robot feedback control; implementation of machine intelligence algorithms. Read more